Films & talks
Films, talks and experiments
A family testimony, my story on stage, experiments in the lab and the making of Project Tao.
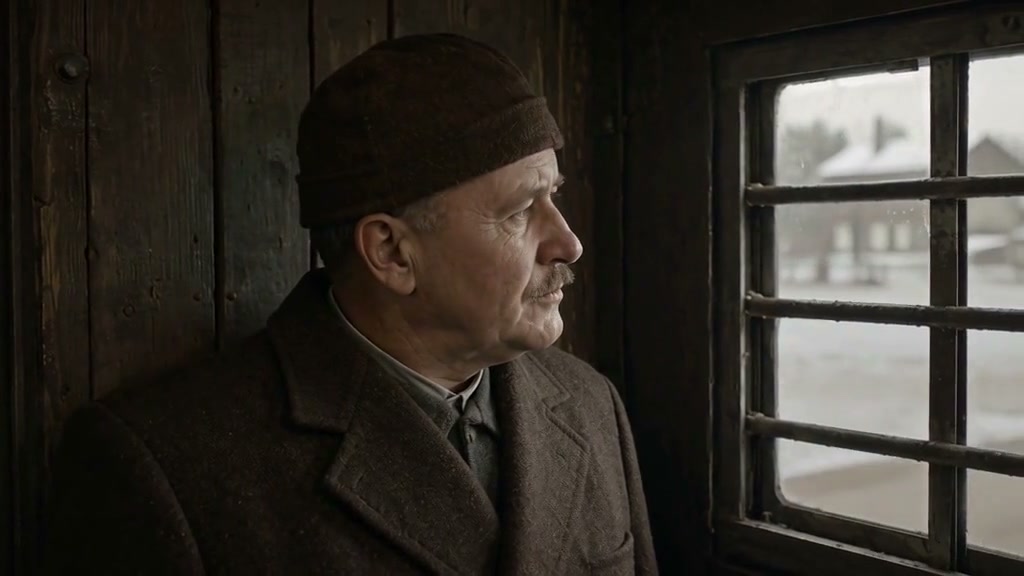
Featured documentary · English · 24 min
The Journey Home
My great-grandfather Pavol Bučan’s written account of imprisonment, a death march, escape and his return home in 1945. The film ends with five generations of the family that preserved his testimony.
Watch the documentary Read the English narration
Featured talk – TEDx Bratislava 2014
My dream about AI
The childhood dream, a difficult start in Plymouth, and the people who helped me find my way into robotics. This is the most personal introduction to my work.
Second Home published a transcript of a separate live talk in 2016, covering my route into robotics and the experiments behind it.
Contemporary Slovak press (July 2014): Staromestské noviny announced the 5 July TEDxBratislava event and my participation. Read the original newspaper, printed page 4, or my biography in the official event programme, page 24.
Origin and story
From student to speaker
An early university interview and conversations from the robotics years.


Robotics, Mars, active vision
Machines learning through body, action, and place.
The research work: humanoid robotics, rover simulation, active perception, and software that made experiments visible.
 Science Museum
Connecting actions with language
Preliminary tests combine object and voice recognition with neural-network training and execution in Aquila 2.0. The film was also used in the Science Museum display.
 ESA / Mars
MSL rover and ODE, autonomous progress
An early rover simulation in which a neural network controls speed and direction.
 NVIDIA keynote
GPU robotics research mentioned at SC11
2011 – NVIDIA – public keynote mention. GPU robotics visible in the wider CUDA story.
More robotics filmsOpen supporting demos
 Robotics
University of Plymouth Robotics
An introduction to Plymouth robotics, made by a South Devon College production team.
 Humanoid robotics
iCub controlled by complex neural networks
A preliminary experiment teaches iCub to touch a green ball using recorded, manually guided movements and a recurrent neural network.
 Simulation
MSLS: Mars Science Laboratory Simulation
An intermediate simulation result: the evolved controller avoids rocks but still fails at holes.
 Research
Active Vision
Preliminary active-vision results using five objects.
 Active vision
MSLS – Active Vision Project
A revised rover model and preliminary active-vision results from the MSLS project.
 Aquila
iCub teleoperation
Human body movements tracked by Kinect are sent through Aquila and YARP to control iCub.
 Aquila
Recurrent neural network on iCub
Initial tests of Aquila training and running a recurrent neural network to control iCub in real time.
 Rover
AUROX autonomous rover exploration
Simulated rover exploration using an evolved neural-network controller, tested across several terrains.
 Applied AI
AICore
A short draft from the AICore project archive.
Cortexica and applied vision
From research vision to applied AI cameras.
These films show the camera years becoming physical: hardware on desks, inference on edge devices, rooms under awkward lighting, and the discipline of making vision survive contact with the world.
 Overview
The Path of Innovation
A retrospective of innovations from my Cortexica years, including AI cameras and applied computer vision.
 AI camera
CortexiCAM – AI cameras based on Myriad-X
A Myriad-X AI camera prototype from the Cortexica years, bringing inference into the camera body.
 Edge AI
AI at the Edge
Cortexica-era work on running AI inference on edge devices.
 Room state
Axis Experience Centre demo
A demonstration of personal protective equipment (PPE) monitoring at the Axis Experience Centre.
More applied vision filmsOpen supporting demos
 Room state
Axis continuous monitoring
A demonstration of continuous personal protective equipment monitoring.
 Room state
Pharmaceutical ingress demo
Protective-equipment monitoring for people entering a pharmaceutical workspace.
 Room state
Construction site monitoring
Personal protective equipment monitoring in a construction-site demonstration.
 Edge AI
Intel featuring Cortexica AI Safe
Intel’s feature on Cortexica AI Safe, from the applied-vision work.
 Visual search
Deep learning localisation and findSimilar
Localising objects in an image and finding visually similar items.
 Industry demo
Cortexica at Smart Factory Expo
Cortexica demonstrations presented at Smart Factory Expo.
Read how the camera prototypes and protective-equipment checks worked.
Spatial intelligence and synthetic worlds
Cameras learning where things are.
Generator and the six-view precursor mark the move from camera outputs to shared spatial understanding: known cameras, controllable truth, and observations that can belong to the same world.


Tao
Tao, built over years.
Three highlights stay here as the bridge from talks and demos into place. The fuller Tao film selection lives on the dedicated Project Tao Films page.
 First paths
Rough ground becoming walkable
The early transformation of rough ground into paths and a walkable place in 2019.
 Aerial memory
Tao from above
A drone view of the land, buildings, paths and planting at Tao in 2021.
 Return
Resurrections
A longer film marking the project’s restart in December 2021.
Observation
Astronomy, optics, and observation.
The astronomy videos stay because they belong to the same older habit as cameras and coordinates: looking carefully, locating things in space, and sharing curiosity in public.
 Observation
Rotating Jupiter and the Great Red Spot
Jupiter and its Great Red Spot rotate across a sequence assembled from telescope observations in Plymouth in September 2010.
 Astrophotos
My amateur astro-photos 1/2
A collection of deep-sky and planetary photographs made with a telescope, DSLR and planetary cameras.
 Astrophotos
My amateur astro-photos 2/2
Astronomical photographs made during my years in Plymouth.