Skip to content Dr Martin Peniak Innovation · Robotics · Project Tao

Curriculum vitae

Dr Martin Peniak

Applied AI · Computer Vision · Robotics

I design and build AI systems that connect cameras, computation and physical devices. Senior Innovation Engineer at Metropolis, formerly Head of Innovation at Cortexica, with a PhD in GPU computing for cognitive robotics.

martinpeniak.com linkedin.com/in/mpeniak

Based in Spain · Updated

Selected engineering contributions

From the research question to a working system.

Spatial intelligence

A shared reference for camera views

Bringing separate camera views into the same spatial reference, so observations can be understood together rather than as isolated pixels.

Spatial calibration case study

Distributed edge vision

Bringing compute to the cameras

Distributing vision workloads across edge devices to overcome the bandwidth and processing limits of a centralised camera system.

Prism: my 2017 project account

Research software

GPU computing for cognitive robotics

Connecting CPU/GPU neural-network experiments, visualisation and humanoid learning through the Aquila research toolkit and iCub.

Robotics and GPU case study

Experience

Professional experience

Senior Innovation Engineer – Metropolis

Continuous role from AnyVision through Oosto and its acquisition by Metropolis.

  • Implemented spatial calibration service v1 to connect camera observations to a shared geometric frame; six-view research combined source images with their 3D reconstruction.
  • Explored controlled synthetic scenes with known camera geometry in Generator, providing a reference for perception experiments; shared the v1.0 demonstration in January 2024.
Spatial calibration and Generator

Head of Innovation – Cortexica Vision Systems

  • Led innovation across machine vision, edge AI and AR/VR, including Prism and OVERPaSS.
  • Developed Prism with the team: a distributed Jetson TX2 vision system addressing five-camera bandwidth and compute constraints, with production use documented in my 2017 project account.
  • Developed edge-vision prototypes including CortexiCAM and PPE demonstrations, turning inference results into visible checks for helmets and high-visibility clothing.

GPU Engineer – Cortexica Vision Systems

Developed and optimised GPU image-processing pipelines using CUDA and OpenCL, alongside deep-learning experiments and cloud and edge systems.

Associate Lecturer (GPU programming) – University of Plymouth

Part-time alongside my research. Prepared and taught CUDA classes; helped establish GPU teaching infrastructure and the NVIDIA CUDA Teaching Center with Davide Marocco and the university team.

NVIDIA research internship – Santa Clara, California

Research internship following my 2011 presentation of GPU cognitive-robotics applications at NVIDIA headquarters. Related public work includes CUDA Spotlight and GTC presentations.

PhD researcher, cognitive robotics – University of Plymouth

Developed Aquila’s CPU/GPU cognitive-robotics toolkit and researched iCub action-language learning and recurrent neural networks within iTALK and POETICON++. First author of the Aquila 2.0 architecture paper.

Mars rover research – University of Plymouth and ESA ACT

My 2008 final-year rover simulator led to Plymouth’s 2009-2010 collaboration with ESA’s Advanced Concepts Team on evolving neural controllers for planetary rovers. Co-authored the 2010 study report and IJCNN paper.

Rover research: my original project account

Education

Education

2014

PhD – GPU Computing for Cognitive Robotics

University of Plymouth. Research on GPU-accelerated cognitive robotics. Supervisors: Angelo Cangelosi, Tony Belpaeme and Davide Marocco.

Plymouth thesis
2006-2007

Life in the Universe

University of Manchester. Distance-learning astronomy course alongside full-time work and BSc study.

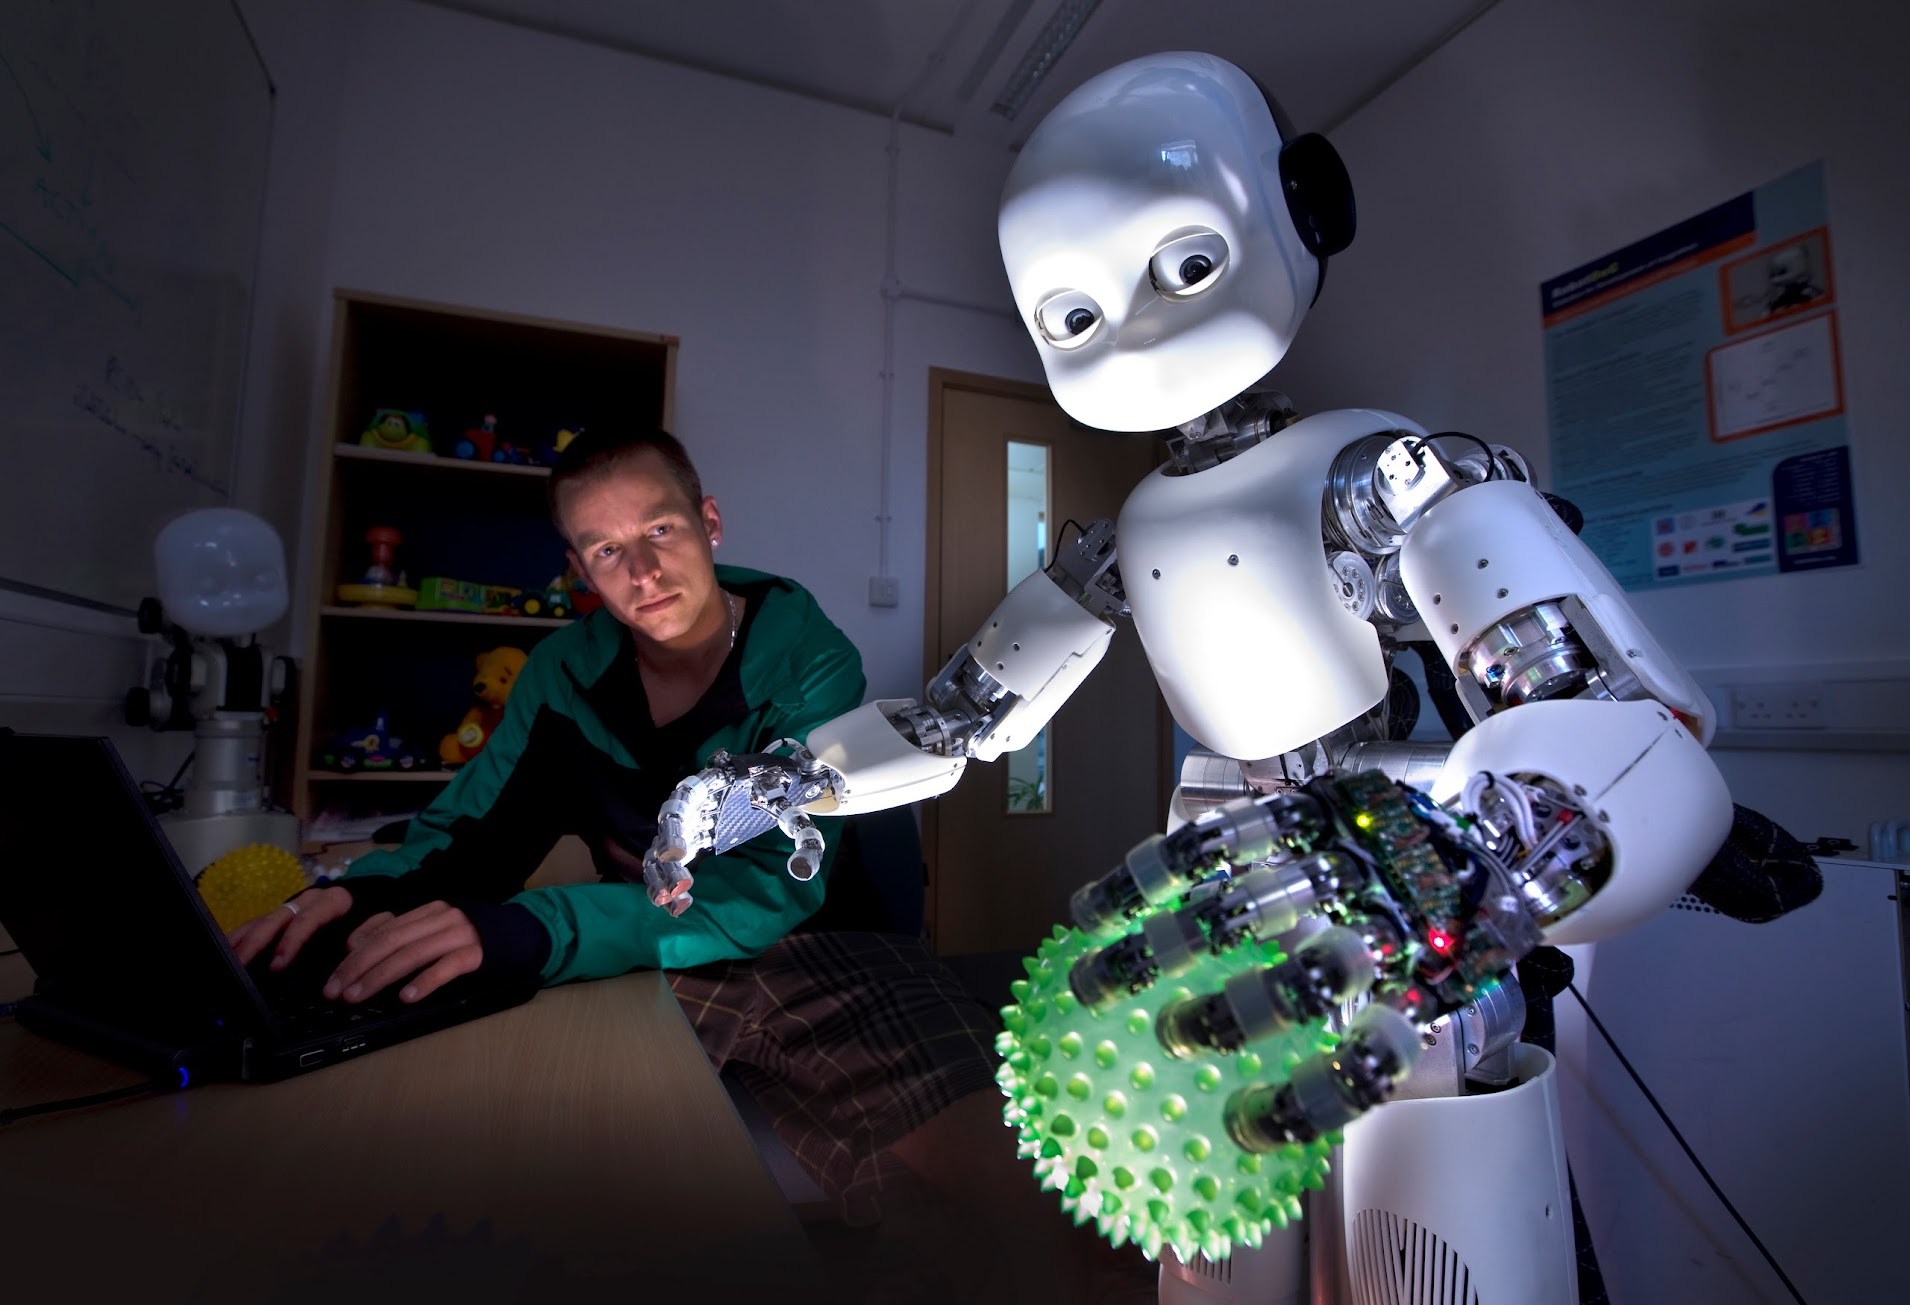
Martin Peniak with the iCub humanoid robot during robotics research

Technical areas

Selected technical areas

  • Perception: computer vision, edge AI, embedded inference and image processing
  • Spatial systems: multi-camera calibration, synchronised capture and synthetic scenes
  • Robotics: neural networks, action-language learning and evolutionary robotics
  • Accelerated computing: GPU/parallel computing and multi-GPU training
  • Software: C++, Python, CUDA, OpenCL and OpenCV
  • Integration: local AI, voice interaction, IoT, Home Assistant and home automation

AI-assisted engineering: I use AI coding and research agents for implementation, source checking and independent review, with automated tests and verification of deployed results.

Independent engineering

Project Tao

I physically build and operate Project Tao, my personal off-grid project: hands-on solar installation, lithium-battery storage, water, irrigation and site construction, integrated with computing and automation. Local AI uses measurements and operating context to support decisions; equipment-control permissions remain separate.

Selected publications

A representative selection. The research bibliography includes full citations, source records, available PDFs and BibTeX.

  • Zhong, J., Peniak, M., Tani, J., Ogata, T., & Cangelosi, A. (2019). Sensorimotor input as a language generalisation tool: a neurorobotics model for generation and generalisation of noun-verb combinations with sensorimotor inputs. Autonomous Robots, 43(5), 1271–1290. https://doi.org/10.1007/s10514-018-9793-7
  • Broz, F., et al. (2014). The ITALK project: A developmental robotics approach to the study of individual, social, and linguistic learning. Topics in Cognitive Science, 6(3), 534–544. https://doi.org/10.1111/tops.12099
  • Peniak, M., Morse, A., & Cangelosi, A. (2013). Aquila 2.0 software architecture for cognitive robotics. In 2013 IEEE Third Joint International Conference on Development and Learning and Epigenetic Robotics (ICDL) (pp. 1–6). IEEE. https://doi.org/10.1109/DEVLRN.2013.6652565
  • Peniak, M., Bentley, B., Marocco, D., Cangelosi, A., Ampatzis, C., Izzo, D., & Biscani, F. (2010). An island-model framework for evolving neuro-controllers for planetary rover control. In The 2010 International Joint Conference on Neural Networks (IJCNN) (pp. 1–8). IEEE. https://doi.org/10.1109/IJCNN.2010.5596942

Research bibliography: martinpeniak.com/publications

Selected talk: My dream about AI, TEDxBratislava (2014).
martinpeniak.com/talks

2012 NVIDIA intern badge for Martin Peniak

NVIDIA

My 2012 research internship

My intern badge from NVIDIA, alongside the interview, poster, and talks about the Plymouth iCub and CUDA work.

Selected work

Research, talks, and projects