2008-2014
Robotics and GPU research
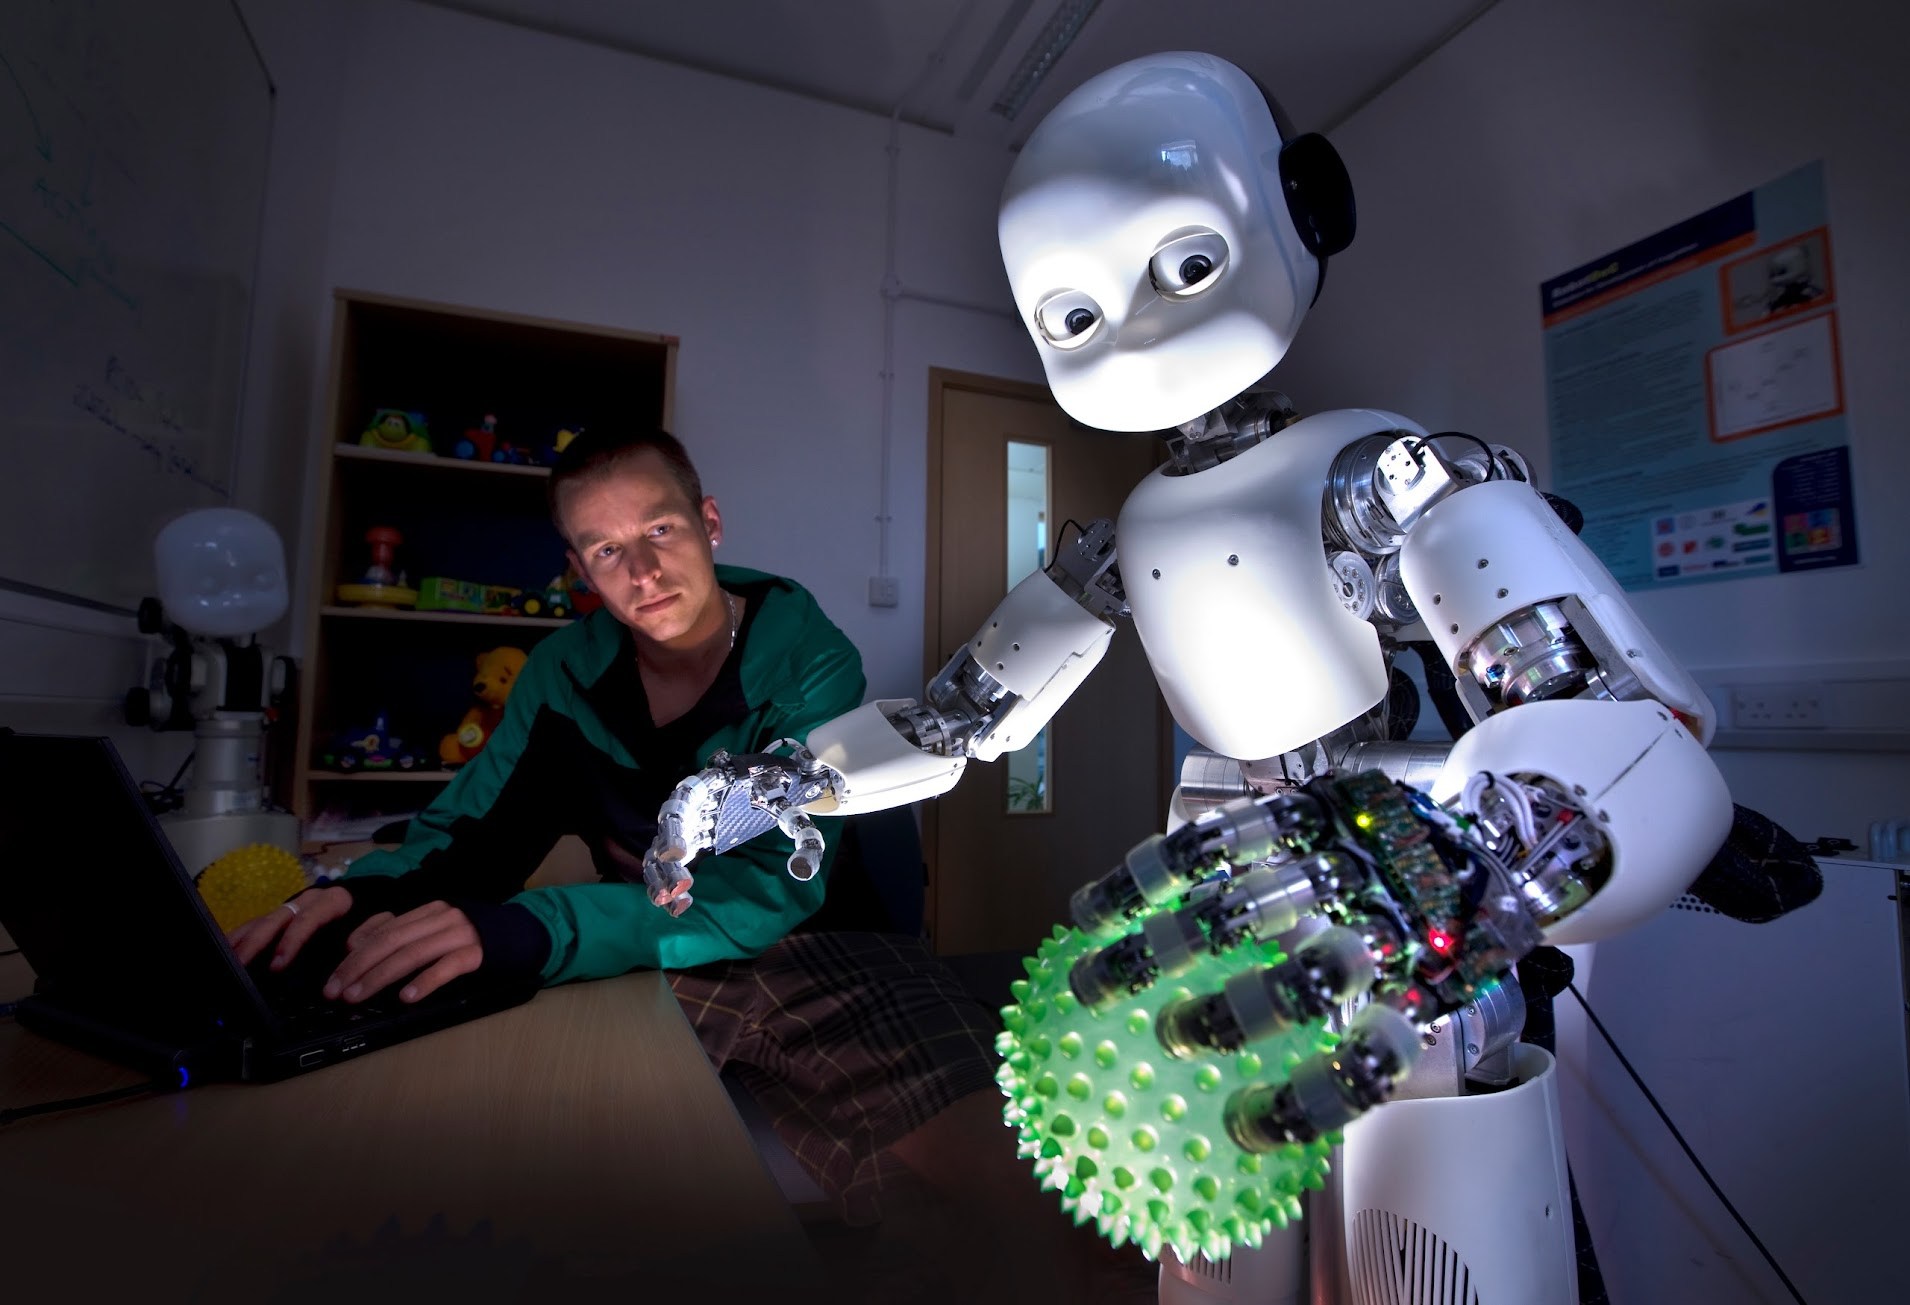
Embodied learning with the iCub robot, GPU acceleration, Aquila, CUDA teaching infrastructure, and ESA rover simulation.
Explore GPU computing for cognitive roboticsWork
Research tools, AI camera prototypes, spatial experiments and an off-grid home. Each project has its own question, challenges and story.
2008-2014
Embodied learning with the iCub robot, GPU acceleration, Aquila, CUDA teaching infrastructure, and ESA rover simulation.
Explore GPU computing for cognitive robotics
2014 onward
Camera-as-computer prototypes, edge AI, synthetic worlds, and the bridge toward spatial perception.
Explore edge AI cameras and applied computer vision
Spatial intelligence
Helping observations share a physical frame: position, timing, topology, uncertainty, and physical context instead of isolated pixels.
Explore multi-camera calibration and spatial intelligence
A personal off-grid build
Turning abandoned land into a home: solar power, stored energy, water, planting, local computing and automation.
Read the Project Tao off-grid systems recordHow it connects
The chapters changed tools, scales, and methods: rover simulation, iCub learning, CUDA, edge cameras, shared coordinates, and finally Tao.